Publications

Publications sorted by year.

Research across robot learning, control, soft robotics, and electronics.

2026
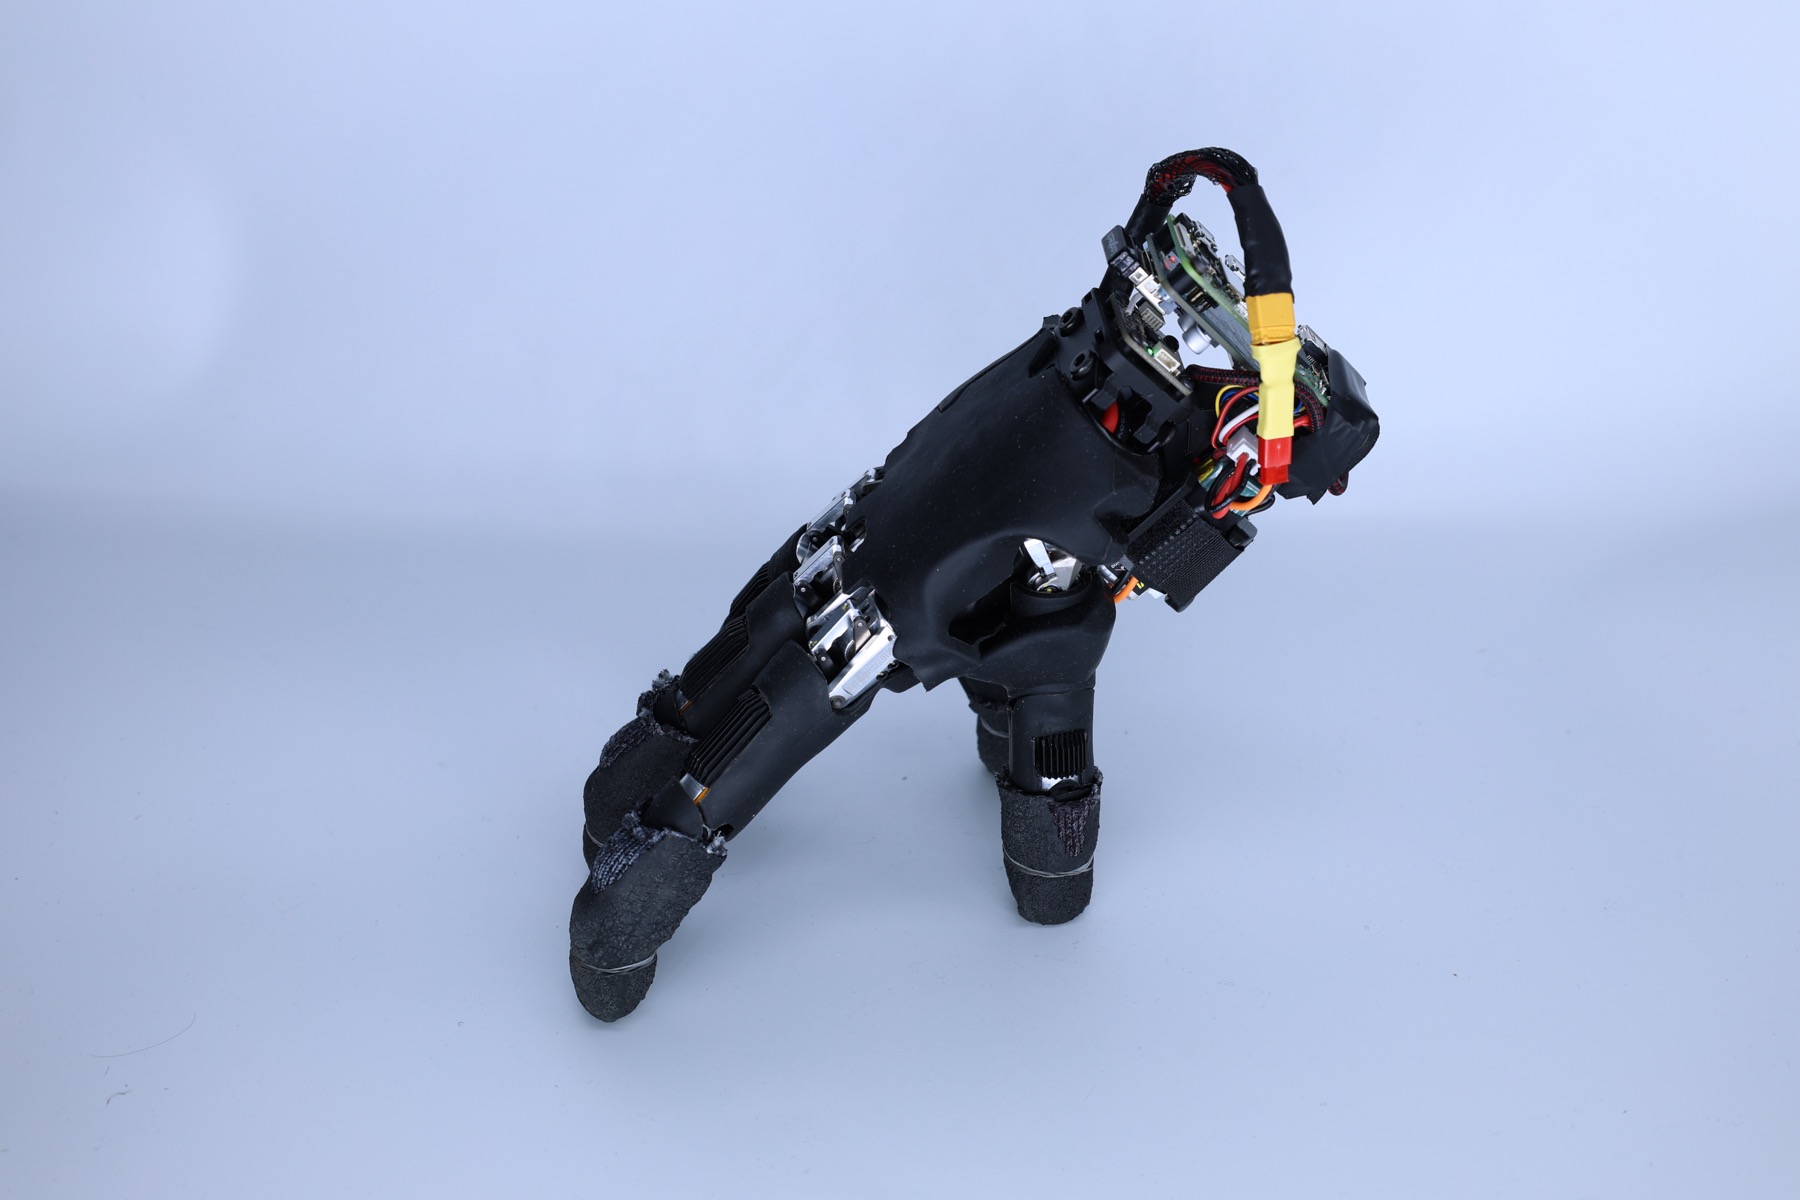
  1. Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand
    Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand
    Amirhossein Kazemipour, Hehui Zheng, and Robert Katzschmann
    Sep 2026
    arXiv preprint
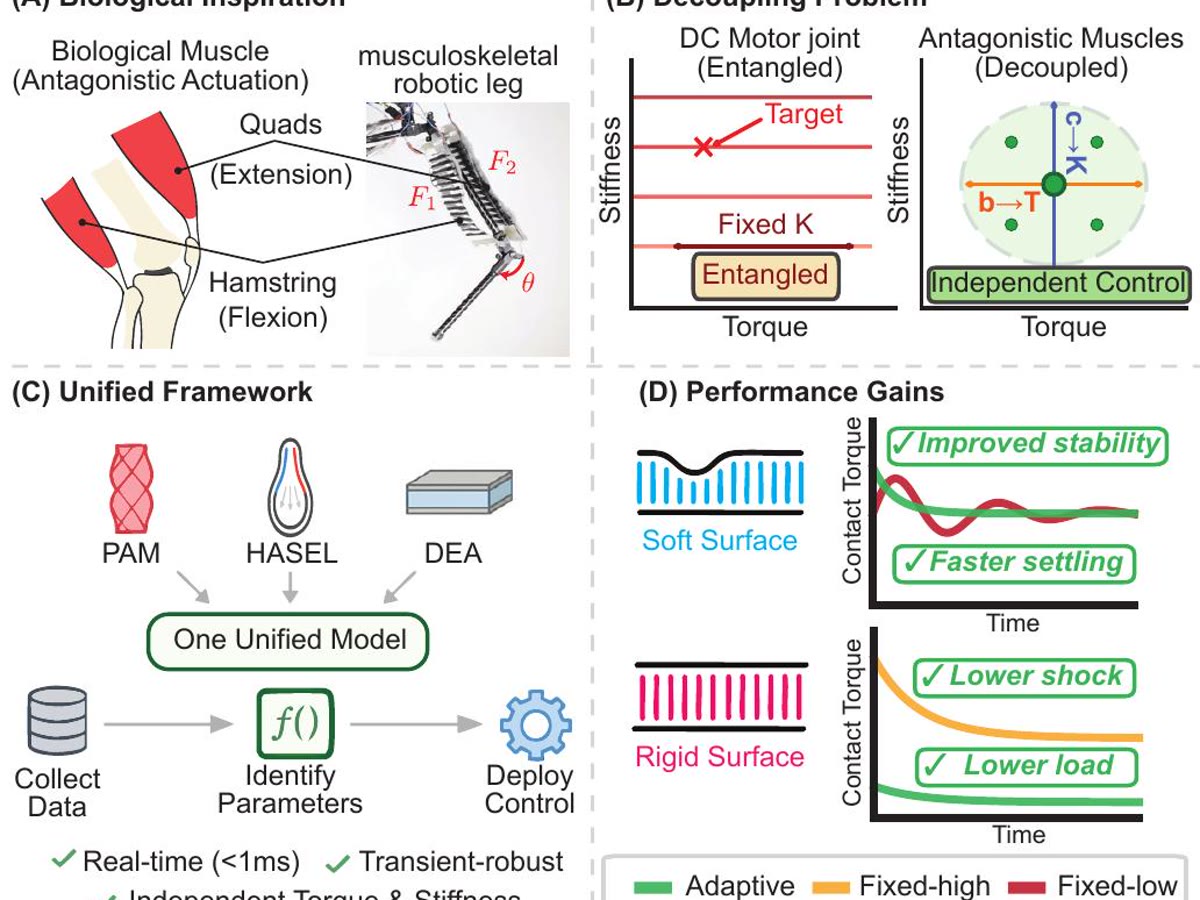
  2. Decoupling torque and stiffness: A unified modeling and control framework for antagonistic artificial muscles
    Decoupling torque and stiffness: A unified modeling and control framework for antagonistic artificial muscles
    Amirhossein Kazemipour and Robert K. Katzschmann
    In IEEE International Conference on Soft Robotics (RoboSoft)(Contribution: first author; decoupled torque-stiffness control with sub-millisecond computation.) , 2026
    Accepted
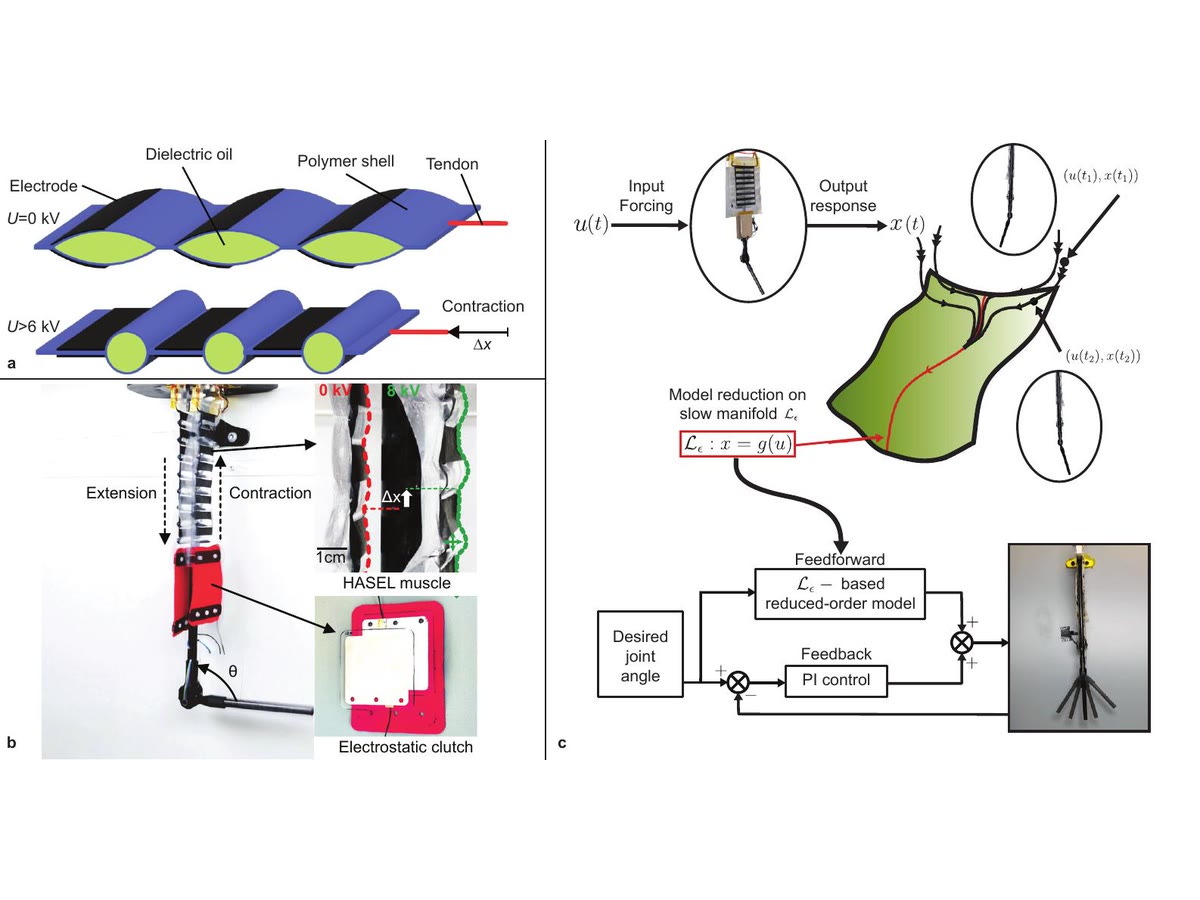
  3. Nonlinear spectral modeling and control of soft-robotic muscles from data
    Nonlinear spectral modeling and control of soft-robotic muscles from data
    Leonardo Bettini, Amirhossein Kazemipour, Robert K. Katzschmann, and 1 more author
    Nature Communications, Sep 2026
    Equal contribution: Leonardo Bettini and Amirhossein Kazemipour.

2025

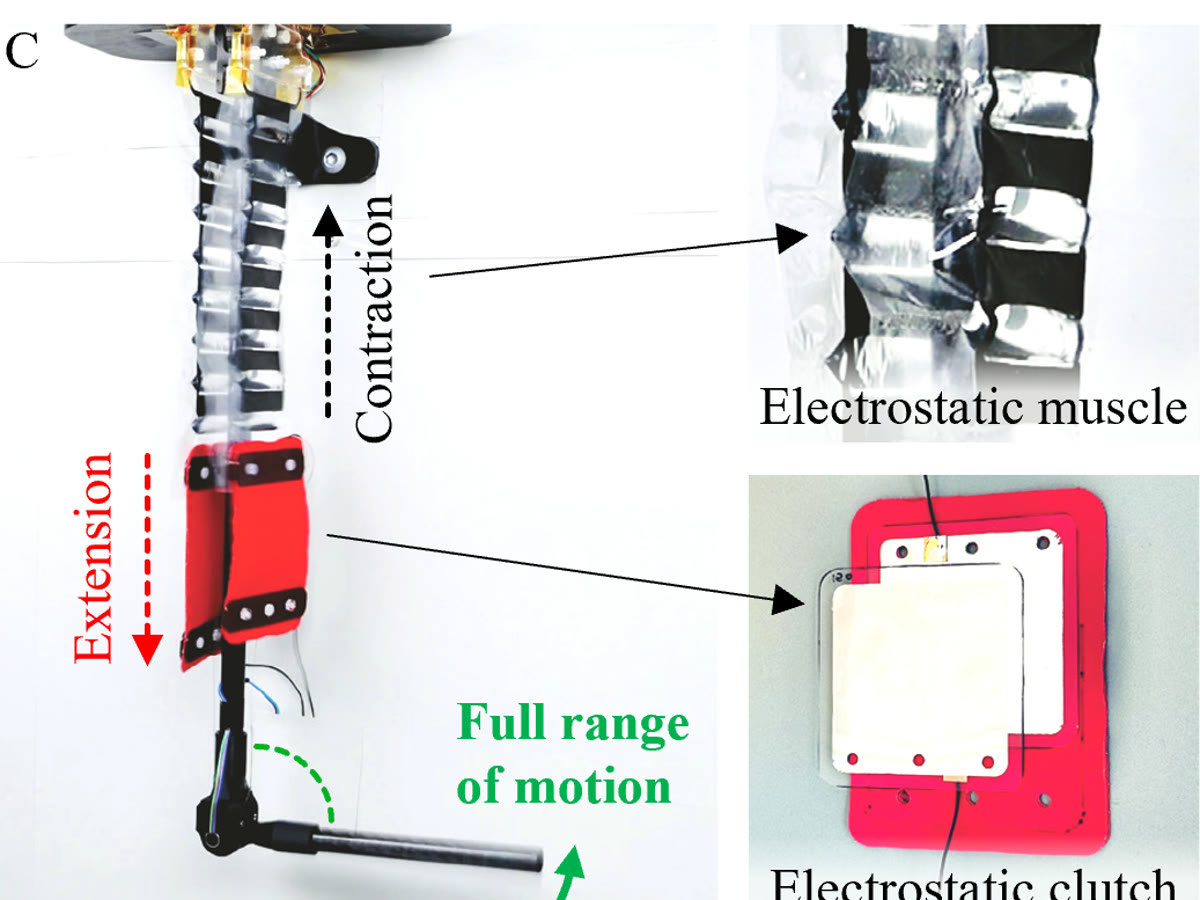
  1. Stretchable electrohydraulic artificial muscle for full motion ranges in musculoskeletal antagonistic joints
    Stretchable electrohydraulic artificial muscle for full motion ranges in musculoskeletal antagonistic joints
    Amirhossein Kazemipour, Ronan Hinchet, and Robert K. Katzschmann
    In IEEE International Conference on Robotics and Automation (ICRA)(Contribution: first author; stretchable actuator design, fabrication, and joint-level validation.) , 2025

2024

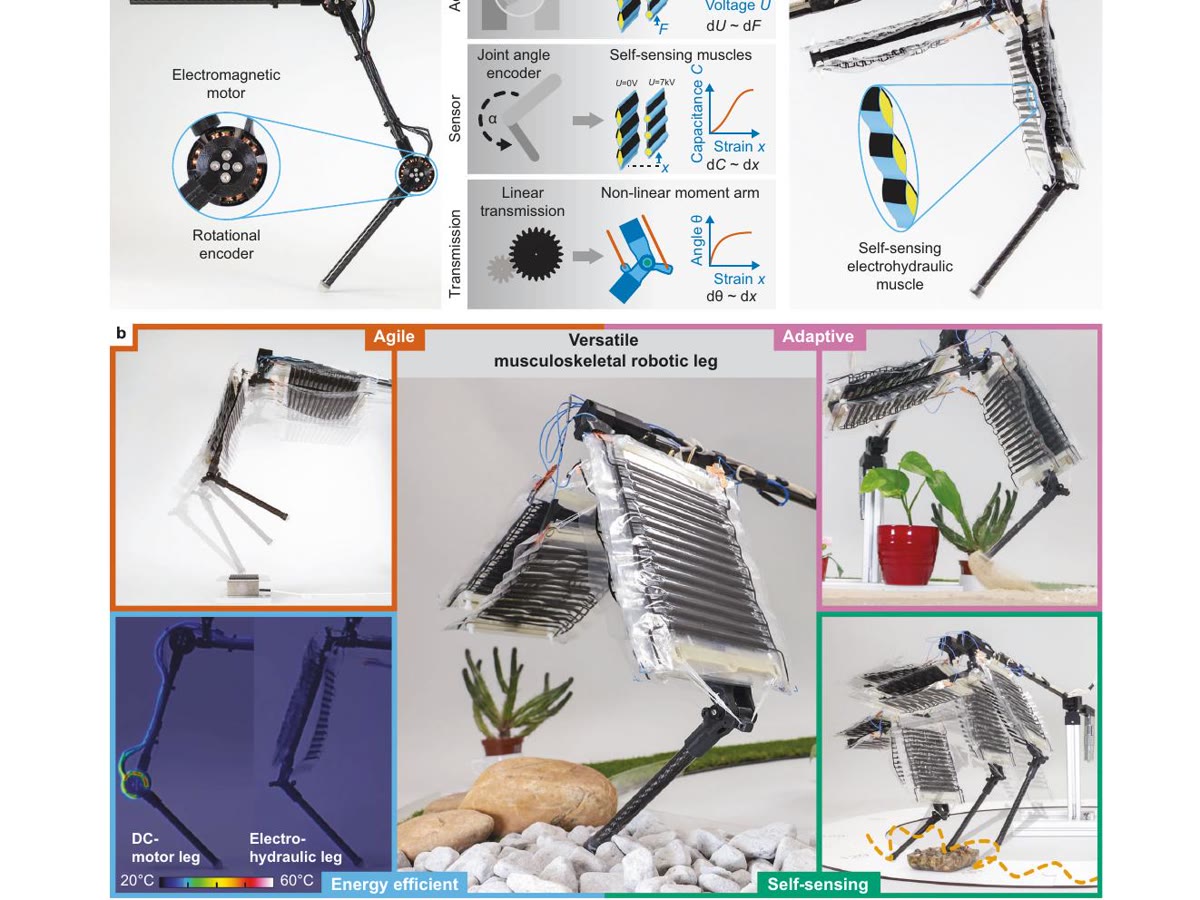
  1. Electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion
    Electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion
    Thomas J. K. Buchner, Toshihiko Fukushima, Amirhossein Kazemipour, and 10 more authors
    Nature Communications(Contribution: co-author focused on real-time control implementation.) , 2024
  2. Low-voltage electrohydraulic actuators for untethered robotics
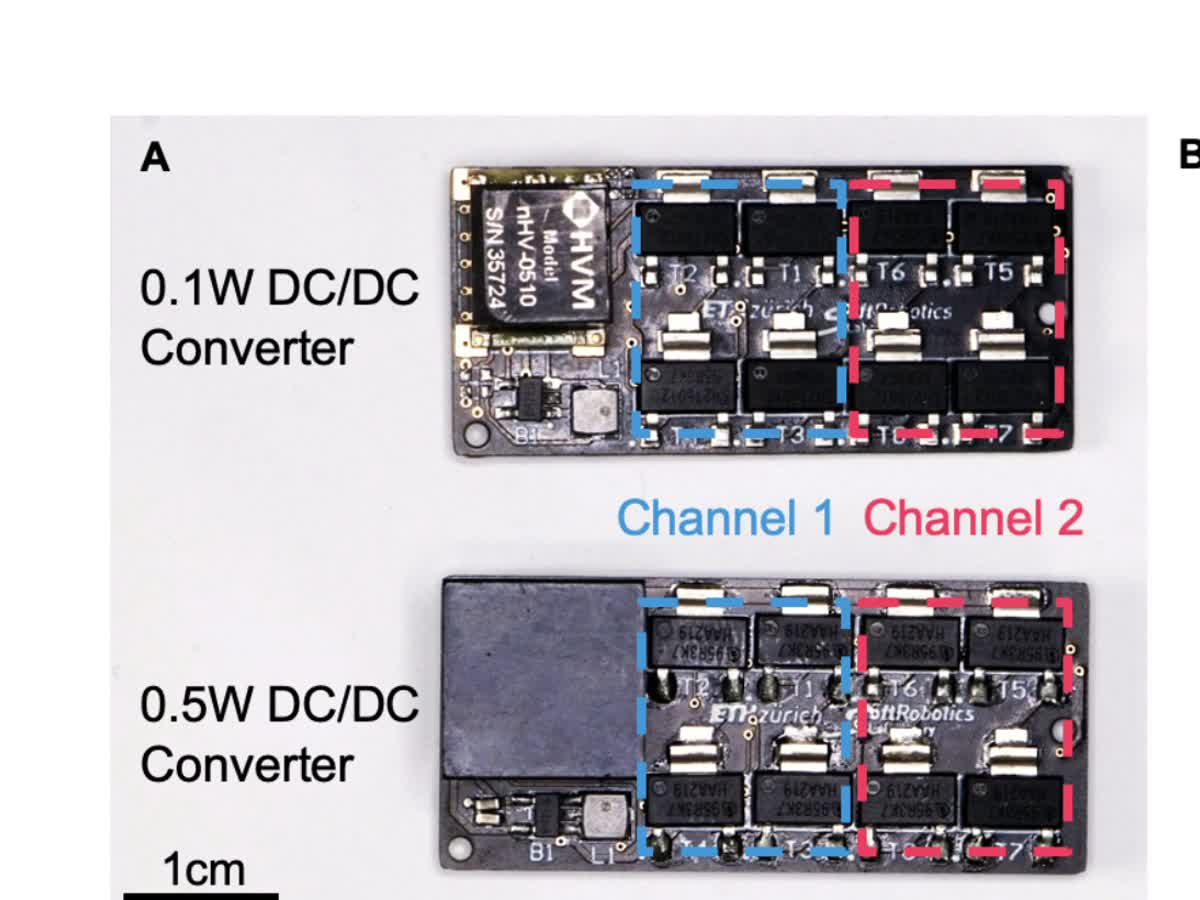
    Low-voltage electrohydraulic actuators for untethered robotics
    Stephan-Daniel Gravert, Elia Varini, Amirhossein Kazemipour, and 4 more authors
    Science Advances(Contribution: co-author focused on high-voltage electronics and PCB implementation.) , 2024
  3. Self-sensing feedback control of an electrohydraulic robotic shoulder
    Self-sensing feedback control of an electrohydraulic robotic shoulder
    Clemens C. Christoph, Amirhossein Kazemipour, Michel R. Vogt, and 2 more authors
    In IEEE International Conference on Robotics and Automation (ICRA), 2024

2022

  1. Kinematic control of redundant robots with online handling of variable generalized hard constraints
    Kinematic control of redundant robots with online handling of variable generalized hard constraints
    Amirhossein Kazemipour, Maram Khatib, Khaled Al Khudir, and 2 more authors
    IEEE Robotics and Automation Letters(Contribution: first author; real-time constrained kinematic control and hardware validation.) , 2022
  2. Dynamic task space control enables soft manipulators to perform real-world tasks
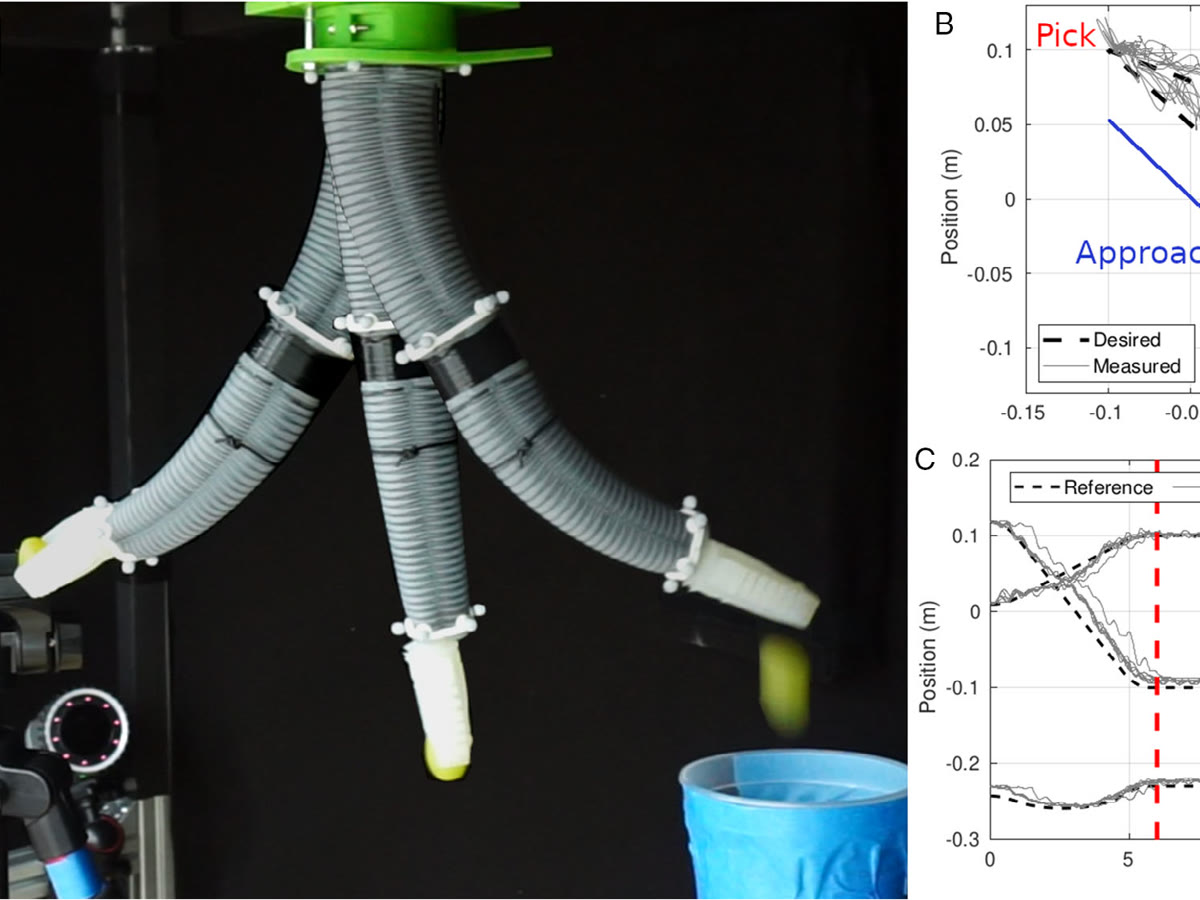
    Dynamic task space control enables soft manipulators to perform real-world tasks
    Oliver Fischer, Yasunori Toshimitsu, Amirhossein Kazemipour, and 1 more author
    Advanced Intelligent Systems, 2022
  3. Adaptive dynamic sliding mode control of soft continuum manipulators
    Adaptive dynamic sliding mode control of soft continuum manipulators
    Amirhossein Kazemipour, Oliver Fischer, Yasunori Toshimitsu, and 2 more authors
    In IEEE International Conference on Robotics and Automation (ICRA), 2022

2021
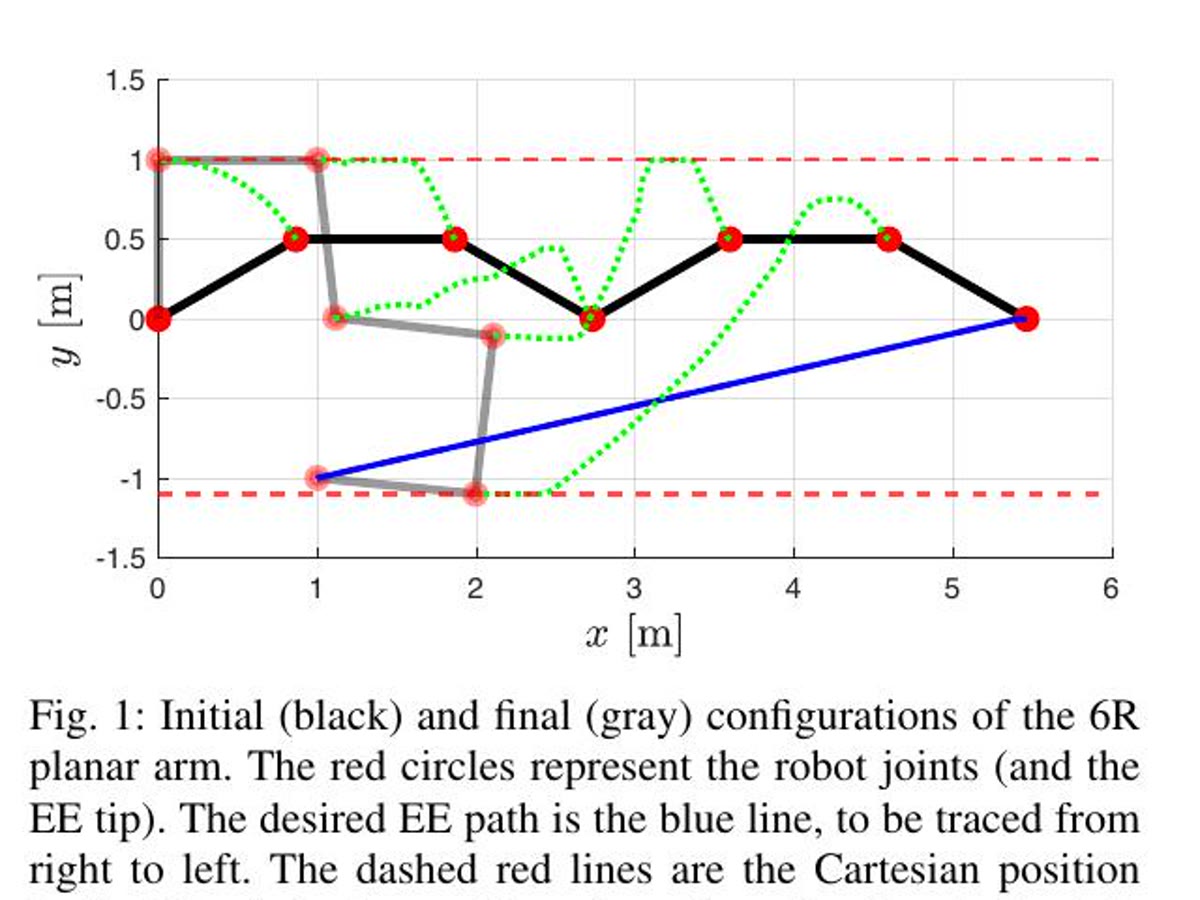
  1. Motion control of redundant robots with generalised inequality constraints
    Motion control of redundant robots with generalised inequality constraints
    Amirhossein Kazemipour, Maram Khatib, Khaled Al Khudir, and 1 more author
    In 3rd Italian Conference on Robotics and Intelligent Machines (I-RIM), 2021

2020

  1. Adaptive fault-tolerant control for active suspension systems based on the terminal sliding mode approach
    Adaptive fault-tolerant control for active suspension systems based on the terminal sliding mode approach
    Amirhossein Kazemipour and Alireza B. Novinzadeh
    Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science, 2020